












This video demonstrates the first water trials of a DIY Arduino-based boat autopilot system, showing how to tune PID (Proportional-Integral-Derivative) controller parameters for stable boat steering. The creators test the system at different speeds (3-5 mph), adjusting the proportional (P) and derivative (D) parameters to reduce oscillation and achieve smooth course maintenance. Key findings include: the D parameter controls oscillation severity (higher values reduce oscillation but may cause over-correction), the P parameter affects how aggressively the system responds to heading errors, and actuator speed significantly impacts system performance. The team also explores the difference between compass-based and wind-driven autopilot modes, noting that compass autopilot is easier to tune as it doesn't account for wind and wave variables.
DIY Arduino Autopilot: Water Trial Performance Tuning
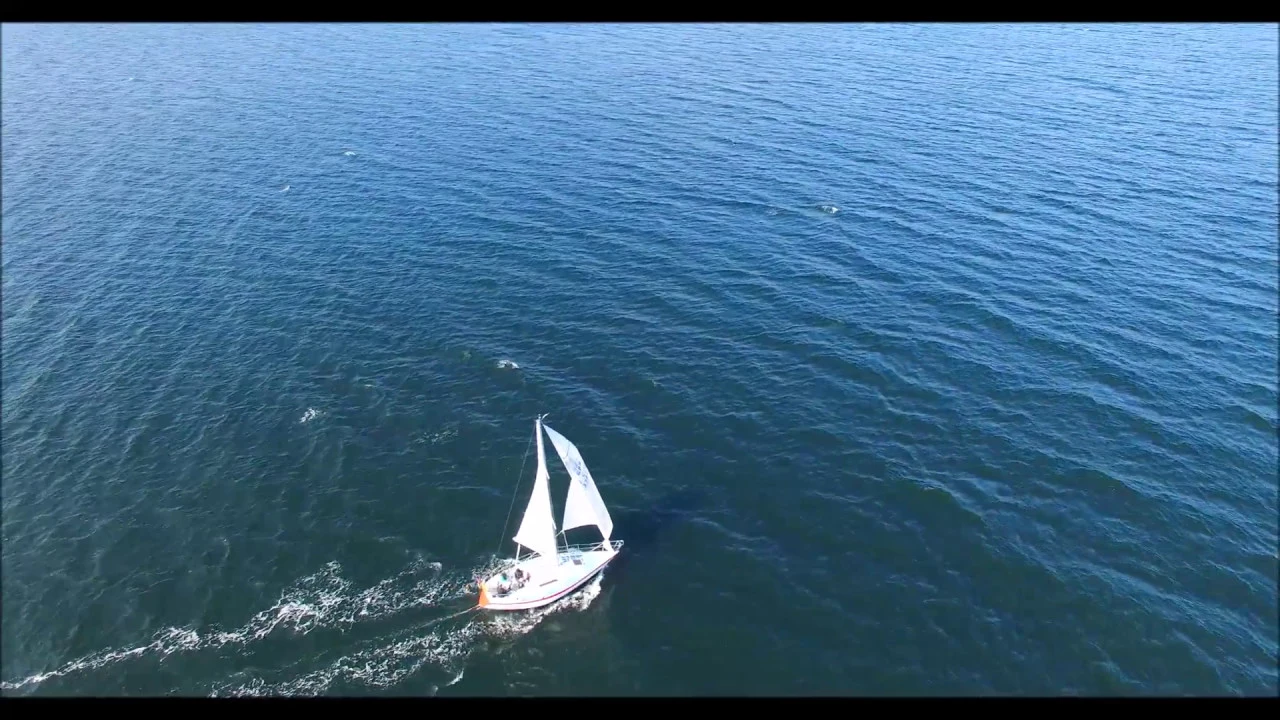
Added:all right so we're out here on bedrock lake um got a slip running at the marina for at least two weeks i'm just doing a week by week that you charge 25 bucks a week so it's not really too big of a deal so i'm going to do is i'm going to hook the actuator up and i'm going to control the boat via the tablet not in autopilot mode just in a manual override mode so i've programmed two buttons for uh manual override just make sure everything actually i'm expecting it to so once i'm comfortable with the steering it manually then i'm gonna enable the wind-driven autopilot without the sail so we're still going to be motoring and i'm just going to see how the pid reacts at different speeds so i'm going to get up to about five miles an hour and kind of tune it get a rough tune on it so that i'm not having to do that while also managing sails so once i get a rough tune and i feel comfortable with the boat uh maintaining a somewhat of a good course then i will um hoist the sails and enable the autopilot in actual sailing mode so [Music] i'm anna and this is ignacio we along with our daughter elena and our pup bae are the new sought selling crew we are diyers with the growing appetite for big adventure our goal is to diy and trade our way up to a blue water worthy boat and set sail on an adventure by sea we are new to selling and plan to develop our selling skills along the way subscribe to stay up to date with our progress and adventure this is the slow speed actuator the the best the high speed actually supposed to show up today at some point but i just figured i'd get out here and try this in which case next time i come out now it'd be no big deal to come out after work i can come out and test that all right so the actuator is installed we're still only doing uh three miles an hour here i'm going to enable my steering and here's a starboard turn all right start straightening back looks like it out a little bit of starburst rotor all right so at three miles an hour the boat seems to be doing fine uh and this is not wind driven this is just me manually so my actuator seems to be fine i'm going to crank the speed up a little bit to somewhere around all right so now the boat's starting to move all right so our cur horse over ground currently is 145.
the boat is gonna get pushed by the wind i don't have this running on compass workforce on the ground right now so uh we're maintaining that 145 pretty well here so i've got the rudder trim exactly where it needs to be now we're at 146.
based on this so you can see my little blue pointer right here and then the wind angle so wind angle is just varying which as expected especially since we're motoring kind of across the wind anyway 1380 of d parameter i'm going to update those parameters and we'll see kind of what how it reacts so if you can see now the actuator's fluttering a lot and and that's just because as it sees it approaching its target it starts backing off on the uh the amount of power that's applied and i may have these two parameters a little too close together but i'm thinking that now we'll maintain our course a little bit better yeah so that's way too much uh d parameter because the boat's just taking a hard turn now so i'm going to back that off to something about 50 of what i'm showing 540 update that we'll see how that reacts so we're at 1080p and 540d 0i yeah so we're still oscillating pretty bad uh i can see it on my lowrance chart here it's pretty good uh pretty visual uh what happens and uh y'all can see what the rotor's doing it's just going back and forth it's never really finding a happy medium hopefully i have no fuel in the boat for those other things to check is going to be 1600 proportional it's updated now that now we're talking about now the boat's basically staying you know within as far as the compass heading if we're just going to lock say we lock in a compass heading uh relative to the current wind it's 90.
and uh see we're we're staying 89 92 88 i mean we're we're staying spot on right here with these parameters and this let's is what's locked in is 1600 p and 540 on the d um so it's uh i'm pretty uh i'm pretty happy with this right here the boat is and it's maintaining pretty close and it's hard to sort of say maybe maybe i should have tried to do a compass autopilot before i did win but you know but i just like to go all in on this thing so anyway it's going to be a future option on here i actually have a button for it and i do have a compass program but i'm just not utilizing any of its information at the moment so it'll probably be easier because uh the variables are more set and uh not dealing with wind and waves and rudder and drift and all that anyway this is doing significantly better so all right so what i'll probably do here is uh drop the keel and hoist the main and uh and see see how the autopilot does with that with the keel down it's going to help the stability of the boat quite a bit so it won't uh it won't go back and forth as much but it it won't help dampen the uh the anemometer input so i may need to look into doing some sort of averaging but we'll see there's just plenty of it's a development thing thanks the beauty of this now is i can motor i can tell it to point straight into the wind hold that with autopilot and then uh voice the sail without having to manage all the lines so that's much better all right so now doing two miles an hour and our wind is apparent wind is 8.6 we're a little bit too close to the wind we're right at 30 degrees so we're borderline sailable with this boat yeah so i may end up needing to uh change my gain you know put a uh basically speed where the faster i go the more it needs to uh to apply but i think a lot of this these issues i'm having will be resolved with the faster actuators some of you had mentioned previous comments all right well the wind has died down to 6.5 and uh sailing this close to the wind at 6.5 is tough especially with only the main i mean if i had the general i would be scooting right now take it slow get this figured out and make sure it's uh good so pretty happy right now with the uh the results i do need to get an hour meter uh an amp meter to calculate how much power this thing has drawn over an hour over an hour just so i know how much battery i need all right battery voltage is 12-1 we started at 12 4. uh we've been up looking at this about an hour so um granted this battery is old and weak for sure i don't know how much i charge this charge controller oh crap [Applause] actuator came disconnected see if we can get back on course here whoops yeah i went down below hang out and uh actuator then became disconnected and now i'm stuck in a o2 all right now that we got all that situated let's see if i can go to the front of the boat while the auto pots going i realize that's a pretty bold move but let me go to the front of the boat while the autopilot's going and see get some cool shots we probably need to shoot the genoa in a little bit do that let me get back in nice calm day all right so our wind you can see has pretty much died and we're coming up close to shoreline you can see how uh how wavy that is i i want to say that waviness is just due to the uh the actuator being too slow i can't speed it up anymore um so it's at least oscillating around its target which is good so um read up a little bit more on uh control tuning just to make sure i'm doing everything correctly um yeah and then see what this new actuator will do a little bit of wing on wing hopefully we don't jive the autopilot's driving force we are like on the verge of driving i guess i hit the tack button on accident we are five degrees from dead down wind [Music] [Music] [Music] we're up this morning got a 20 mile an hour wind coming from the south now mae is not too thrilled we won't be out here all right so i gave it a huge error and it uh it's oscillating real bad so i'm going to increase the d somewhere around 900 there we go 960.
that seemed to do the trick the wind is uh the wind's really kicking us around right now but uh increasing that d parameter has uh greatly reduced the oscillations and the waves are just throwing us around so it's kind of a it's going to be tough to maintain something perfect but hey dizzy good pup back in the safety of the marina if you enjoy our videos please like subscribe and share them with your friends
Up Next
Arduino IMU PID Control System Design and Tuning
@paulmcwhorter
67K views•2020-02-06

Damped Free Vibration of Structures: Viscous Damping Theory
@IITKanpurNPTEL
23.4K views•2019-08-26

Polymer Environmental Degradation: Mechanisms & Stabilization
@iit
1.8K views•2012-07-10

How a Student's Question Saved a NYC Skyscraper from Collapse
@veritasium
22.8M views•2025-04-26
Related Study Plans & Knowledge Roadmaps
Structured learning paths in Engineering