


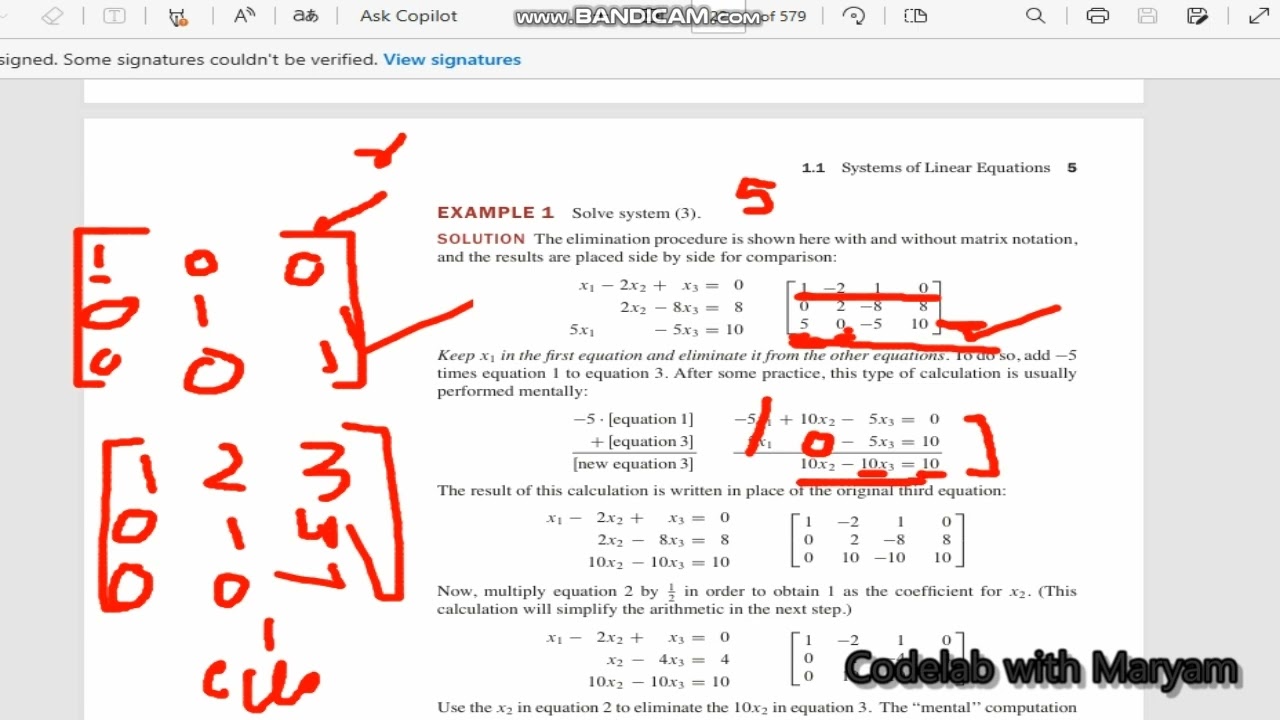




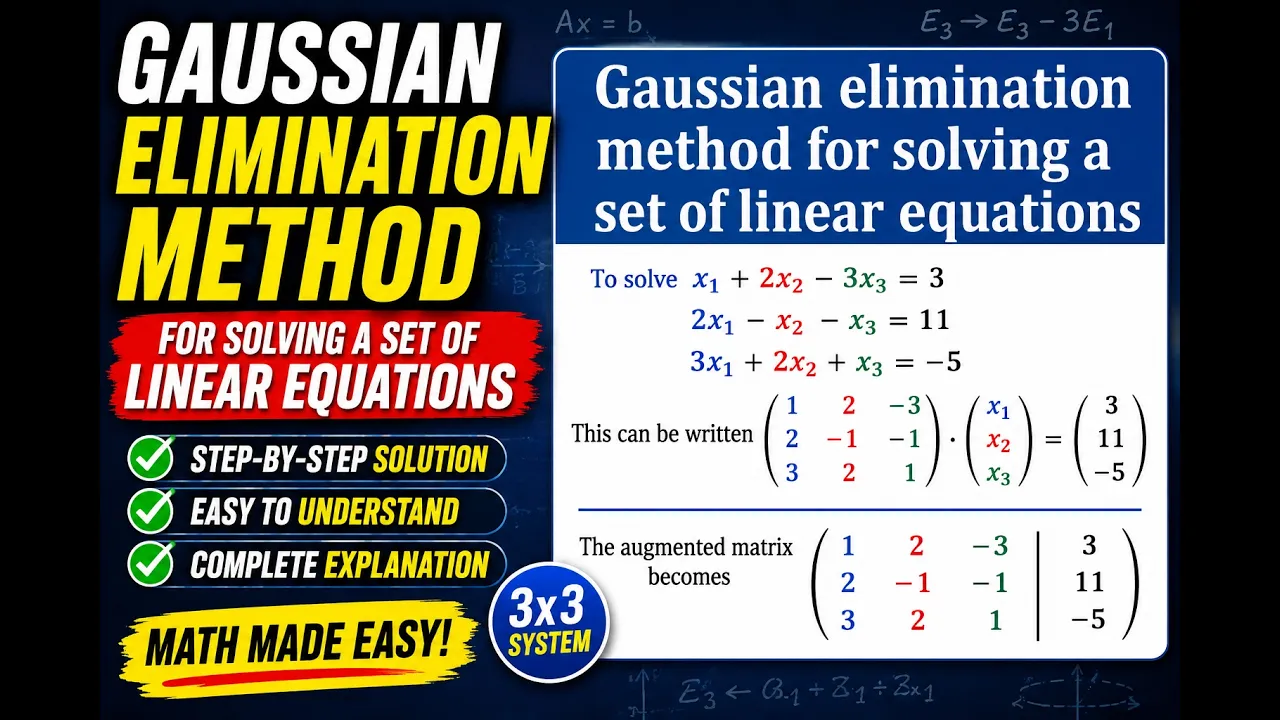










Gaussian elimination solves systems of linear equations by transforming the augmented coefficient matrix into an upper triangular form through row operations (swapping rows, multiplying rows by non-zero scalars, and adding multiples of one row to another), then solving via back substitution; when a zero pivot prevents elimination, row swapping resolves the issue.
Solving Linear Systems by Elimination | MIT Linear Algebra
Added:Familiarity with algebraic methods for solving basic 2x2 and 3x3 systems of linear equations.
Understanding of matrix notation, including how to represent a system of linear equations as an augmented matrix.
Fundamental knowledge of elementary row operations, specifically scaling rows and adding multiples of one row to another.
A conceptual understanding of what it means for a system of equations to have a unique solution, infinitely many solutions, or no solution.
Applying back-substitution to extract the final variable solutions from the upper triangular matrix resulting from elimination.
Mastering LU Decomposition, which formalizes the elimination process by factoring a matrix into Lower and Upper triangular matrices.
Understanding elimination failures, including how to handle zero pivots using row exchanges (permutation matrices) and identifying singular matrices.
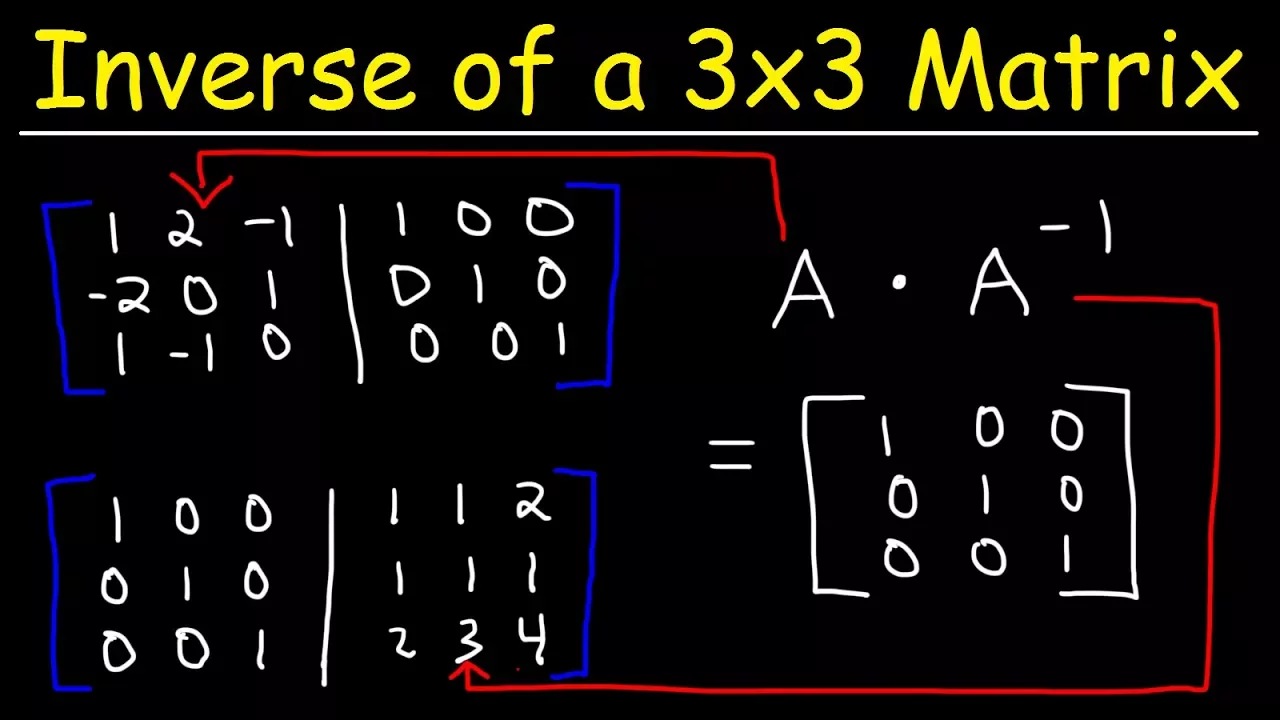
Extending Gaussian elimination to Gauss-Jordan elimination to compute matrix inverses and reach Row Reduced Echelon Form (RREF).
Connecting elimination to foundational vector space concepts, such as the null space, column space, and finding the complete solution to Ax = b.
419.6K views4.6Klikes10:17Original Release: 2011-12-09
Hi, welcome to recitation. My name is Martina and I'll be your recitation instructor for some of these linear algebra videos. Today's problem is a straightforward solve the following linear system with four equations and four unknowns using the method of elimination. The system is x - y - z + u = 0 2x + 2 z = 8 - y - 2 z = - 8 and 3x - 3 y - 2 z + 4 u = 7. And although you might know different ways to solve this system at this point, the method of elimination is going to show up million time a million times during these um videos. So it's really important to get it right. So, I suggest you try solving this system now using the method of elimination as it was described in class. I'm going to leave you alone with a problem. You should pause the video, solve it yourself, and then come back and compare your solution with mine.
And we're back. So, the method of elimination, if you remember it from class, consisted of replacing this system with an equivalent system.
equivalent meaning they have the same solution uh by a series of row operations. Row operations are not supposed to change the solution to the system and therefore example exchange the order of two equations. Multiply an equation with a non-zero number and add a non-zero multiple of one equation to the other. So let's do that. As we're going to do this series of arithmetic operations, we don't really want to copy the names of the variables and the equality signs every time. So we're going to keep the important information which are these numbers, these coefficients here. We're going to keep that information in a matrix.
So let's write a matrix.
Each row is going to correspond to an equation and each column is going to correspond to an unknown. So the first row is one minus one minus one one.
The second row corresponding to the second equation is 2 0 2 0. And you want to be very careful to put zeros on the right spots here.
The third equation is 0. Left myself enough room. 0 - 1 - 2 0.
And the fourth equation, fourth row corresponding to the fourth equation is 3 - 3 - 2 4.
And as we care about the right hand side as well, we're going to copy this information as well and get the augmented matrix of the system. 0 8 - 8 7.
Okay. And now let's try reducing this matrix to an upper triangular one.
We start with the first column and we're going to use this number called the pivot to get rid of all the numbers under it. So to get zeros here and here.
A way to do it is well to get rid of this two I have to multiply the first row by minus2 and add it to the second one. This is not st writing this here is not strictly necessary but I like to do a bit of bookkeeping because I'm prone to make a lot of errors uh while doing these simple arithmetic operations and then if I get to the end figure out I made a mistake somewhere this bookkeeping makes it easier to backtrack and find find the place where I made this mistake. So we replace this matrix with another matrix. The first row stays the same. 1 - one - one 1 0.
The second row gets replaced by a second row -2 * the first row. The aim of that is to get a zero here. So that's good.
Next on this position here we get min -2 * -1 which is 2 + 0 which is two min -1 * -2 which is 2 + 2 which is 4 - 2 + 0 which is -2 and 8 - 2 * 0 which is 8.
The third row already has a zero here so I can just copy it over. 0 -1 - 2 0 - 8 and to get a zero here I'm going to multiply the first row by minus3 and add it to the fourth row and get zero -3 * -1 is 3 -3 is 0 um -3 -1 of sorry 3 - 2 is 1 and -3 + 4 is 1.
And there we go. The first column looks like a first column of an upper triangular matrix. Now let's do the same to the second column. This is going to be our pivot, the number that we use to get rid of numbers under it. And we see that to get rid of this number here, we will need to multiply it with 1/2. So multiply the whole second row with 1/2.
and add it to the third row. The matrix that we get will have the first row the same stays the same. 1 - one - one 1 0. The second row stays the same. 0 2 4 - 2 8.
The third row gets replaced by the third row plus 1/2 times the second row and becomes zero zero 2 - 2 which is 0 -1 + 0 which is minus one and 4 - 8 which is minus4 and the third row the fourth row already has a zero here so I just copy it over zero 0 1 1 7 And now let's look at this matrix.
It has the first two columns as they're supposed to be zero under the diagonal.
And now we want to get a zero here.
Normally what I would do is to circle this number here. Multiply it by something so that I get a minus one and add it to this row to get a zero here.
But that's not going to work. You might remember from lectures that zeros can never be pivots or you can just try finding a number such that 0 times this number equals minus1 and seeing that such a number doesn't exist because you're always going to get zero. So we cannot proceed as we did until now. But is there another way to get a zero here?
There is a very simple row operation which consists just of switching the third and the fourth row. It certainly doesn't change the solution of the system. So let's do that and let's get the next matrix which is 1 - one - one 1 0 0 2 4 - 2 8. Then we put the fourth row here. 0 0 1 1 7. And we put the third row here. 0 0 0 -1 - 4 and there it is. This is an upper triangular matrix. So in the same way as at the beginning we had a system and then wrote a matrix representing it.
This matrix also represents a system and this system has the same solutions as the initial system but is much easier to solve. Now let me write this back as a system and let me do that not starting from the first equation but starting from the last equation.
So the last equation here reads minus u equals -4 which is as equations go pretty easy to a pretty easy one to solve.
The solution is u = 4. Now let's go back to the third equation. And the third equation reads y uh no I'm sorry z.
The third column corresponds to z plus u equals 7.
But we know what's u now. So it reads z + 4 = 7 which just becomes z = 3.
The second equation is 2 * y + 4 * z but z is 3 - 2 * u but u is 4 = 8.
And from this one can easily compute that y is equal to 2. And finally the first equation reads x minus y minus z + u equals z or x = 1.
And this is our solution. x y z and u equal 1 2 3 and four. This finishes the problem. But I would very strongly encourage you now to take this solution and plug it back into the original system and check if it's really a solution. And that's all I wanted to say today.
Up Next

7:11
Vector Spaces Explained | Linear Algebra Intro
@publicitygetslarge
117.8K views•2010-03-14

8:17
JEE Maths | Circles: Pole & Polar Explained with Equations
@TargetPublications
14.4K views•2019-02-23

20:22
Cantor's Theorem: Proof & Diagonal Argument | MIT 6.042J
@mitocw
33.1K views•2016-09-12

6:00
The Mathematical Impossibility of Accurate World Maps
@Vox
23.3M views•2016-12-02
Related Study Plans & Knowledge Roadmaps
Structured learning paths in Mathematics
mathematics
Projective Geometry: Coordinates & Conics
01From Euclidean to Projective Space
02Homogeneous Coordinates
03Duality and Projective Transformations
+ 2 more learning modules
14h5 modules
Explore Roadmap
mathematics
Tensor Calculus: Vectors to Riemann Curvature
01Mathematical Foundations: Linear Algebra & Calculus
02Covectors, Dual Spaces, and Tensor Basics
03The Metric Tensor and Index Gymnastics
+ 2 more learning modules
40h5 modules
Explore Roadmap
mathematics
Gödel's Incompleteness: Logic, Proofs & Limits
01Introduction to Formal Systems & Hilbert's Dream
02Set Theory, Cardinality, and Cantor's Diagonal Argument
03Arithmetization and Gödel Numbering
+ 2 more learning modules
14h5 modules
Explore Roadmap
mathematics
Galois Theory: Fields, Groups & Solvability
01Foundations of Abstract Algebra: Groups & Fields
02Polynomials & Field Extensions
03Splitting Fields & Symmetries
+ 2 more learning modules
24h5 modules
Explore Roadmap