










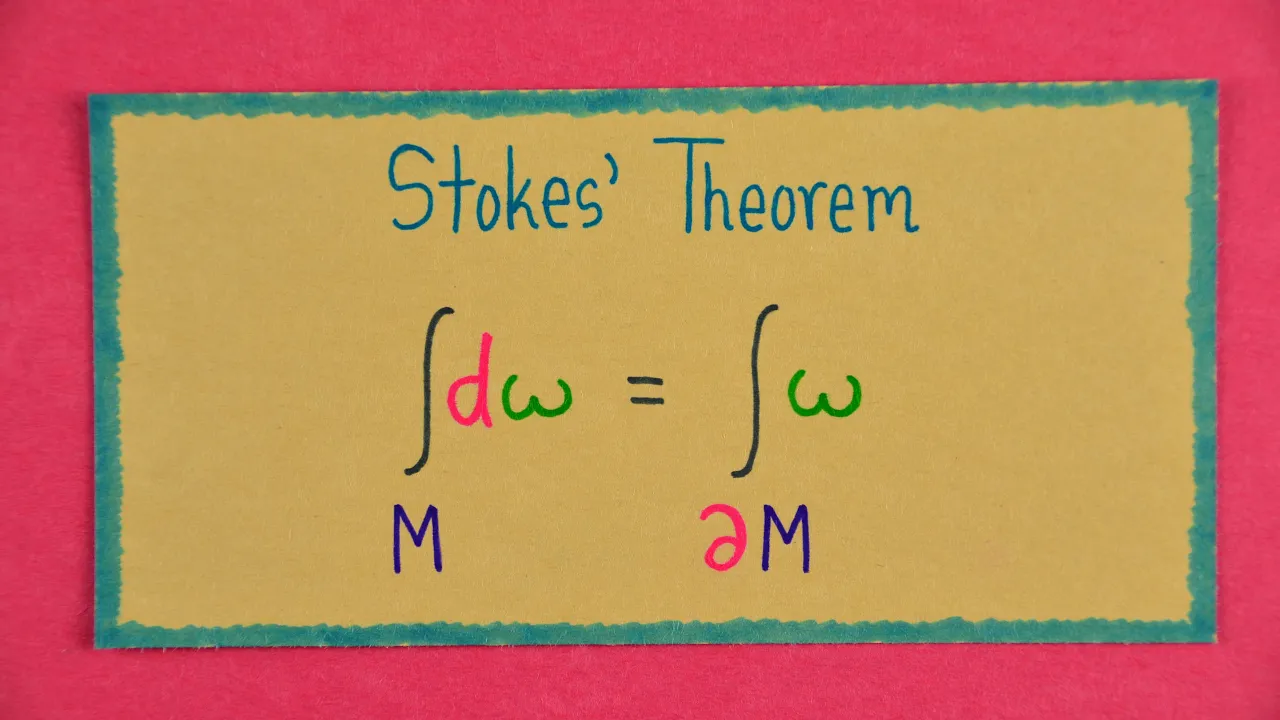








Integration on manifolds requires a volume form (a nowhere vanishing top-degree differential form) and a partition of unity to handle overlapping coordinate charts. The integral of a function f over a region U is defined by pulling back to coordinates via a chart φ, multiplying by the volume form expressed in coordinates, and integrating. For the entire manifold, one covers it with a locally finite collection of charts and uses a partition of unity (smooth functions that sum to 1 and are supported within each chart) to avoid over-counting contributions from overlapping regions. This framework allows integration over submanifolds by approximating them with simplices and using the boundary operator to relate integrals over boundaries to integrals over the interior.
Symplectic Geometry & Classical Mechanics: Lecture 6 - Manifold Integration
Added:hello welcome last lecture we looked at we began the theory of the integration of forms on a manifold so we didn't quite integrate anything in the previous lecture instead we introduced the notion namely that of a volume form so volume form Omega is a nowhere vanishing in form of on a manifold of dimension M so if you have a M dimensional manifold M P game so if Omega is a cave and in form and it vanishes nowhere then it's a volume form so these things are rather special because they allow us to build theories of integration on manifolds and as we'll see we can use these objects on lower dimensional sub manifolds and also develop a theory of integration of a sub manifolds as well that's going to happen soon but now we're going to go through a little bit of drudgery to build up this theory of integration before we can use it in all its glory before I do that I'll just remind you that if you if M is orientable that implies there exists such an ami go now whether or not this is the right omega that depends on extra data so it turns out then at this stage we don't really have enough structure on our manifolds to select out a canonical or correct volume form and in fact if you want to get a canonical volume form you need a data of at least a Riemannian metric when you have one of those things then you have enough extra data to say what you think the right volume is for a piece of a manifold so this means that the theory of integration we're going to build will be a function of something that's arbitrary like we won't have the we won't be able to select as a right one we will just build up a theory and whenever we have such a volume form then we'll be able to do a theory of integration and then to choose the right one we'll need extra data such as Romanian metric or some extent symplectic structure good that was what we did last week and now let's actually do some integration so let F be some function from our little M dimensional manifold to the real numbers real but real valued function they live inside calligraphic FM these functions and that suppose that someone came and gave us a volume form or that we just had a reason to prefer one particular volume form this stage we have no reason to prefer one over the other so that's fine or sometimes we call these things volume elements as well and then to build the first step towards our integral defining our integral on the manifold we're gonna take well a coordinate neighborhood so that's a pair of an open set u some function Phi from our little M dimensional manifold to our M there's u by RM and on this manifold we have this volume element Omega and we have some function to the real line that's hardly the data we have and given this this data that's actually enough to build a definition of what an integral of f over the little region you looks like what what is this thing we can give a definition for that so the idea behind the definition we're going to supply is simply the same idea we've been applying throughout this review of differential geometry namely whenever you've got something on the manifold quickly get it onto our M where you know what to do once you've got it on our M then you're good right because there you could use multivariable calculus to do whatever you wish so that the main difficulty is in associating to a function here a function down here and then once you're there you can more or less define an integral just by analogy with the mini variable calculus case and okay we're just going to define this thing and then so f times Omega is again an M form F C functions it's just a number times by an M form so the integral of the M form F Omega over U is defined to be so this symbol here whenever you see it don't try and interpret the symbol first replace the symbol by what's on the right hand side of the definition so you first do an integral over a region in RM namely this region and what do you integrate well you want to integrate a function from RM to R how many functions are there from RM to R well there's one canonical one there's one there's one function that you would naturally right there on and that is first do Phi inverse to go from RM to the manifold and then do F I hope I got it the right way around this times F composed with Phi inverse so we need a function from RM to R we have a function right there F composed with Phi inverse and we have a little bit more actually that we need we need you know this volume form here has to play a role somehow and it's going to play a role when we express it in terms of this coordinate basis here so I'll add in that extra information here so this h LM this little H comes from expressing our volume form Omega in terms of the coordinate basis is DX 1 through 2 DX n I should put those as superscript and I guess for consistency I mean I'll put them as superscript up here although that distinction is not really made in many variable calculus so there it is that's what you do whenever you see this you have immediately go to the coordinate representation for tommy-gun take your function f H is also a function from RM to R and just replace that symbol by this symbol and you're good to go because this is something you do know how to process it with many variable calculus now why would you choose the definition to look just like this and not different I mean what's with the H right maybe you could just drop the H and just why not take it to be this well it's all got to do with what happens when you go from one shot to another you want that you that things in the intersections between two charts that these definitions match up that they will define and that's why you have to choose things this particular way because when you change bases remember volume forms change bases in the right way to match how the integration measure changes under a change of coordinates so that's why it looks exactly like this to make that notion well defined because it's very tempting right well it's tempting for me for you it's tempting just to say well why bother with volume forms it looks like we have enough data here already we have the manifold we have you I didn't you know that you could write down this is a mini variable function from RM to R why don't I just define the integral according to the normal integral here with just the DX one through the DX M forget this H nonsense why not well if I was to then look in another patch then there would be a problem when I compute the integral in the intersection between two charts and the volume form is exactly the thing exactly the extra information that tells you how to change integration measures between patches so I hope that if you if you're troubled by this definition if you ponder like why doesn't the naive esting work that you'll be sort of convinced after a while looking at different charts that it can't work in general you need this extra data of a M form we go okay that's great so we can integrate over a coordinate chart supa dupa but that's not like integrating other m is it so that presents further challenges how do we integrate a function of all of them surely that's something that's we should be able to do all right you can do it but you need extra information so first the first step is to at least cover em with a bunch of charts if you can't cover em then what that's hopeless so we want to cover it with open sets that's actually the word open is kind of important here although you'll never notice it in examples locally finite means that every point is in the is in it most a finite number of these sets and covering means what it means that if you take the union of these u j's you get em so let's suppose we've covered our manifold with a bunch of open sets locally finite very important open also important and the idea is simple right how am I going to integrate f well I just integrate the function over all these charts and add it up right but you should see a problem here if you do this if you cover em with a bunch of open a locally finite collection of open sets let's see what the problem is we're defining an integral over m so here's a here's a really good example of a manifold it's the 2-sphere let's cover it with open sets you could imagine doing this right so we cover the sphere with little little circles is it locally finite well I mean I can't prove it to you with this picture but that point there is in three open sets and so on right you just look around is every point you know most a finite number well yeah there's even just a finite number of open sets here so it's locally finite these are open we don't include the boundary and now let's imagine we have some function f - the real line okay how are we going to define the integral over the manifold so easy isn't it right integral of F Omega is equal to question mark exclamation mark what's wrong with this exactly will be over counting some of the contributions that's a bit of a problem isn't it see if we this particular point here will get counted like three times in this integral definition over here this is a bad definition you can define it but it's just like it's clearly not right it's a bit frustrating now we're gonna fix this up so the way to fix it up is you agree on a way to fix the over-counting in the intersections so a way to fix you of accounting would be to like say okay I'll only take 1/3 of the function from this we're going to do the integral over that one 1/3 from that 1 and 1/3 from that one seems simple enough right should work but now you have to be SuperDuper careful you have to be very careful that is indeed the right thing to do you agree on every point that the that it gets over countered that the other counting is dealt with by agreeing on an amount to contribute from each of the patches that it's in it's indeed what you do but you have to be careful because that method of a green of how much of the integral from this patch here do you take in this patch here and this patch here that's like some weighting of these three integrals there that weighting is itself a function and you want to make sure that that function is integrable I mean it's possible to use the axiom of choice to to construct some extraordinarily Berkeley complicated function that will at every point give our weighting that's that adds up to one but is that function integral is that a riemann integrable function or the beginning of a function all we know is that smooth functions can be integrated so the weighting whatever we chooses our weighting functions has to be smooth and then it's really not clear if you can agree on a weighting which is smooth smooth smooth across these patches so let's at least define the thing or after and then I'll say a couple of words about proving that that thing does exists we can indeed find a smooth family so where was I up there definition so we're continuing this definition continued over there so if we have a family of functions epsilon J and these epsilon J's go from UJ to R so if this family in this family will turn out to be a weighting scheme satisfy some conditions then it's a good weighting scheme so firstly if you want to have a weighting then it's got to be above zero otherwise you're like it's not really a waiting anymore is it so the value of our function of each of these functions has to lie between zero one you know we want to wait l in each of these integrals and the over counting regions by something like a probability and secondly we want that these functions are identically 0 if well here I've got to put in a coordinate if Q is not in UJ that is well possible right and there's a further requirement well is it possible actually I guess I'll say a comment about this in a minute the function is gonna be differentiable yet be exactly zero outside of some let's say compact region is that even possible should worry about that and you want that the sum of all these functions and this is since this is a locally finite collection of open sets there's a finite number of these things in each of these sums you want that that's equal to one for all points in the manifold your question so the question is isn't this equivalent to the support being in the closure of you yes the support is the closure of the set with an open set right yeah yeah yeah that's exactly right that's not what's written here that's true yeah that is true yeah okay that's it's not very nicely formulated so the support of epsilon J which is closed we won't be and what we really want to say is that yeah that's not not quite correctly formulated so if you have a bunch of differentiable functions that satisfies these criteria here I mean give it a name it's called a partition of unity such a thing if it exists oh partition of unity subordinate to you J if you can find such a thing if such a bunch of functions really did exist then they would be exactly the right things to put in here to find an integral over your m because it would deal with the over counting in every point so we'll just assume that such a thick bunch of things exist yep so the question is we don't use weaker than smooth functions in or the integral converges no no it's not convergence it's to do with Integra bility at all because you can you can construct non integrable functions very very easily if they're not smooth continuous is enough but but they suppose that you know where does it say apart from here so these functions have to be continuous differentiable is stronger and implies continuity and so everything's fine that's what that's why that's there and so I was expressing the counterfactual point that if these functions were not even continuous and it's not clear what to do and it seemed better but they're not continuous weighting functions are easy to dream up so the difficulty is in dreaming up a bunch of our partition of unity where these epsilon czar continue at least continuous or if not differentiable right so that's the difficulty right there yes smooth it's important that the functions are smooth yes that's not making a strong point here if the functions aren't smooth then you're in for trouble maybe that's yes that's right if you choose a nonce non continuous partition of unity you wouldn't do that right that's why at least continuous should be in the notion of partition of unity but why not work within the category which we're working in which is that of smooth and differentiable functions so that's why we add differentiable there but now I want to make the point that not continuous positions of unity are easy to make that's trivial you just at every point just choose a probability distribution but differentiable partitions of unity do they even exist there's a tension here between this criteria here this adjective differentiable a tension between that and these three three criteria here and so that challenge that tension we have to resolve that and I have to at least say some words about you know do these things exist and obviously they do because I've put it in a definition but you know I have to explain to you how to resolve this tension well firstly let me least write out the integral I mean I hope it's kind of clear now so property 3 implies that for all points in the manifold f you can add in one write F of Q times one is f of Q and what does this do well this defines a bunch of functions F of J of Q so for all Q in the manifold we see that F of Q is the sum of these f of J's and E's f of J's and none other than these things these F of J's are smooth functions so they're integral and hence oh yeah if L so FJ equals zero outside the U of J's and so the integral of F over m it's given by just the sum of these integrals like that it is a little exercise sure that you get the same answer if you chose the different Atlas so I say a couple of words about these Epsilon's these partitions of unity however raise them where after there's still the Epsilon's up there we're after functions that are smooth because we want to what still retain or remain in the category of smooth functions as morphisms but we also wanted a function that that is smooth yet vanishes outside plants on finite region so if you can convince yourself that such a thing exists then I hope that the construction of a partition of unity becomes plausible so the main difficulty a claim is in finding a smooth compactly supported functions the main difficulty of building one of these partitions of unity and once you've got one then you can use it you've got to stretch it and deform it and then use it to construct these epsilon J's so we're after a function f with a basically if you can do it from R to R then you can do it from RN to R and then you can do it from coordinate patches we're after a function f that goes from R to R that is smooth so you can differentiate at an infinite number of times and these are riveters that continuous and for example f of X is exactly zero outside of some interval say minus one to one because once you've got one of these these little beasties then you can stretch it deform it multiply them take their products to get further compactly supported smooth functions now I've been sort of careful to say the word smooth and not analytic here so it's a de-stressing theorem that there does not exist it doesn't exist a compactly supported analytic function so what every physicist wants but you don't get to have it these functions must be non analytic I'll show you a couple of steps of how to construct such a thing you might start to wonder is it even possible at all so the it's you got to build you've got to have start somewhere and so I'm going to show you a very special function that is compact not compactly supported but vanishes identically in some region and not in another and is smooth and here's the magic function right here it's e to the minus 1 on X for X is greater than 0 and 0 for X is less than equal to 0 this is a very magical function so this is this is all sort of fundamental building block to get get these things here start thinking about that function so when X is really small X is positive but really small then you've got 1 over X in the exponent here but that's really big and e to the minus something big is really small so this is obviously getting very very close to 0 as 0 as X goes to 0 from the right and what about when X is extremely very large when X is nearly infinite then that's like 0 and e to the 0 is like 1 so that's a kind of interesting function and now all i've just argued is that this function goes to 0 near 0 and is 0 to the left what about the derivatives do all the derivatives exist well start differentiating it you'll get some function x by e to the minus 1 over x that function will be a polynomial in 1 over x and as X goes to zero the exponential beats at every time so it will exist the derivatives with respect to X exist so it's smooth it's not analytic but it's smooth so let's draw this function what does it look like well it's easy to draw right so it's zero here this is X and over here it's one estimate publicly over though it's one it sort of comes in you can draw it on the computer if you want and it sort of mu becomes identically zero there now the trick to building something that's compactly supported well I've got that function haven't I I know how to construct this I could use this use translates of this function now couldn't I I could translate it to the left so you move it left by one unit this is obviously compactly this is not compactly supported but it obviously vanishes left of minus one I could take a reflection of this function that would also be one of these functions and I could take the product so like this I could multiply two of these guys so this is this function here is what did I call it I didn't give it a name let's call it f GH e d CC so that function there is C of X plus 1 all right when X is minus one then the argument 0 so that's this one there and this dotted function here is C of reflection minus X minus 1 and if you take their product you can define a function B of X to be C of minus X minus 1 times via C of X plus 1 boom that is a function definitely is 0 outside of minus 1 and definitely 0 past 1 and it's smooth there is a product looks exactly like this if you plot it it doesn't quite go up to 1 you just read rescale it a bit and then you're done you found yourself a nice function that's compactly supported it's identically equal to 1 see here now that's not quite the construction we actually want a function that's identically 1 on some region identically 0 on another region and smooth in between I'm not going to show how to construct that but you can see by doing a transformation which scales infinity into down to one that we can get such a function so I haven't given anything resembling a proof that partitions smooth partitions of unity exists what I've shown you is how to construct a smooth function I've argued how to construct a smooth function that's identically 0 outside of some interval to get a partition of unity you want to build functions that are identically 0 outside of arbitrary compact sets and our identity outside inside an arbitrary compact set and to do that you use some combination of these functions and scalings and mappings thereof and then you gotta argue that that you can extend one of these compactly supported smooth functions to a collection of them that add up to one everywhere it actually turns out to be not so difficult to carry out that proof you just have to be a little bit careful then that shows you the existence of such a thing and then you can at least write down an integral and then this exercise shows that that integral is independent of the partition of unity and of the charts you choose so if you go look up the proof now I think at least and think it's in the book of warned on differential manifolds they go through the gory details of constructing this partition of unity you'll see that the the ideas are they're already captured by this argument that I've given it's obviously a pretty good idea to do integrals of functions on manifolds this is something you might want to do it's a good thing right and what we want to do is extend this notion of integration down to sub manifolds but before we do that let's do an example so you can see how this works in action let's take our favorite manifold s1 the circle here I've drawn it embedded in r2 and we're gonna have two charts on our circle we can't have one chart there's no way to continuously map a circle to the real line and so we're going to take two charts we can take a chart that goes around this part of the circle there but does not include this point here so this point is excluded in chart number one and we will take another chart which goes around here but doesn't include that point so those are our two charts of the circle they're all meant to be on the circle it's all meant to be on this one so let's just define some charts right here some coordinate functions Phi so Phi 1 inverse I'm going define it by the inverse maps from the interval 0 to 2 pi to the circle by the following function give it theater and it will hand you cos theta sine theta so when theta is 0 this is 1 comma 0 at this point there when theta is 2 pi just rolls around oh yeah it's this we don't have 0 in the interval so when theta is 0 it is that point there but that point is not included so this is actually a chart you one here and that's chart you two so as theta rolls around the interval 0 to 2pi 5 rolls around that chart u 1 and we've also got Phi 2 Phi 2 is exactly the same but it goes from minus PI to PI exactly the same functions in fact oK we've got ourselves nice to a nice atlas of the circle s1 it's colored by two charts and we have the coordinates right there you should go ahead and work out the transition functions it's an exercise all right let's do an integral let's integrate cos squared theta on this one and we know the answer right it's an embedded manifold we can go ahead and work out the answer the old-fashioned way but let's tie our hands behind our back and do it as using our definition of integrals and so for that we need some partitions of unity and we have one by choosing epsilon one is sine squared T over 2 and epsilon 2 is cos squared theta on - let's check is this a partition immunity does it vanish outside of U 1 so epsilon 1 has to be compactly supported well it is it has to vanish outside of U 1 and it does so in one point that you have to worry about namely theater is zero and there it's exactly 0 and epsilon 2 that's exactly the same property but for you two and then we choose as our integral as a volume form just D theta in the coordinate chart and then let's do our integral so integral over s 1 of the function cos square theta d-theta is the sum you one goes to zero to PI I skipped a step no I didn't skip a step and it's a fun little exercise to show that's 1/2 PI plus 1/2 pi like that's just PI tests your antiderivative skills it's look me finite you add them all up but only a finite number will ever be nonzero at any point so that so you can do sums of untenable sets as long as any finite number of terms in on 0 its exact example of a compactly supported analytic function isn't it the support does not indeed lie when you want to but you can define the integral here with limits so it works out fine in this particularly it's a particularly degenerate example because the coverings the charts open sets which exclude one single point so everything has to be smooth so that you can extend the limits of these integration to the full compact region it is all right we've got a workable notion of integration on a manifold we can take a function on a manifold integrate it get a number as long as we have this data of a volume form and a partition of unity but that position immunity is guaranteed by locally finiteness and and the other and the other axioms of a manifold as a locally Euclidean space but what about integrating over sub manifolds how are we going to build up such a theory and one way to build up well it's not obvious certainly not obvious if you have some manifold m and then you have some sub manifold m in of m in this case a line how do you build a theory of integration using what we have there it's not completely obvious what to do one way and this is a way we will adopt in this course is to break your sub manifold up into little pieces approximate them with like straight line segments or little triangles or something like that and then pull everything back to a low dimensional subspace of RN and then just use this theory of integration there so that's very very very very roughly the way of building an integration over sub manifolds and so we're going to do now and to get started on that we're going to talk about integration over simplices you can talk about how to break up a manifold into chunks and then do an integral over that chunk and this is different from the coordinate charts this is these are really special subsets of m so we're gonna start in our M where our end in this case with we understand things very well you can introduce two very special sets subsets of RN we have a notation for the thing the standard n simplex in our M RN denoted Sigma bar n also denoted with angle brackets Piedmont through to PN is the convex hull of the point P naught to the P n where I got to tell you what these peanuts to the piensa unoriented standard simplex so these P naught what is P naught was the origin P 1 is the unit vector along the x-axis and P n is the unit vector along the N axis and this convex hull means all the points in the any convex combination so set of points X such that X is sum of PJ that's really a shame that means P pj times by SJ XJ alright where the some of these X J's is 1 and the X J's are greater than 0 that's what convex hull means take all convex combinations of these basis points PJ why do we have p0 just the definition of the standard simplex there's more than one definition out there I agree but this is the standard simplex in r2 so the convex hull of these three points here sorry that now it's possible to define the standard simplex by not including P naught and then you have this one-dimensional guy and then in three dimensions you would have a triangle and so on but then the dimension of this object is one lower than the ambient dimension so you know we do it this way now this is the unoriented standard simplex and I've denoted it with angle brackets here you can see that this definition yupi not through the pn it could be just arbitrary linearly independent points in RN and that definition here makes complete sense right it's just the convex hull of these points whenever I write angle brackets P not through to PN I mean the convex hull of those points now that simplex is not oriented there's no sense in which it has a handedness to it there's no inside and outside let me put it this way there's no chirality or handedness to the object you can't say it's left-handed or right-handed you can't say you go along the simplex in one direction and there's another direction you could go along it so I'll give those words more precise meaning in a second so we want to give this thing an orientation so if I do arrows on it like that then that's kind of somehow an orientation of this simplex and we want this notion of orientation because we want to talk about integrating a longer path and along the surface and for that we need to talk about what does the word along even mean so for that we're going to need the word of the word orientation to be defined a simpler the best example is the the one simplex that's a little line segment and you can talk about integrating along a line right but you can also talk about reversing the in the limits of the integral of going backwards to pick up a minus sign right and so we're going to extend that notion through to all the N synthesis here it is here's our first we're going to build it up kind of inductively this notion of orientation so Sigma one with round brackets notice the difference here there's angle brackets before now this round brackets so we can depict that we can draw it's perfectly clear what the word orientation means in one dimension it means you decorate the the interval with an arrow and the arrow tells you that it's oriented from P to P one so you can talk about the other orientations to orientations possible of a line segment you can point it that way you can print it that way so if you point it that way it's obviously the same as just having P 1 at the beginning and P naught at the end but we're going to use the notation very suggestively that this we're going to define this symbol here to be that why are we going to do that well later on we're going to add and subtract simplices we're going to turn them into a free abelian group we're going to allow ourselves to take two simplices and add them we're going to add them like putting coefficients in front of them and then having formal finite sums of these things so that but at the moment we're not we haven't done that right I've just said that's the notation for that later on we'll actually interpret that as a minus sign in some abelian group so an orientation in higher dimensions is just a decoration of the faces with errors let's go to two sympathies so we've managed to deal with orientation of one sympathies cool we're done so what does P naught P 1 P 2 mean in that order it means that you put arrows on these edges like so it just tells you the order in which you traverse the edges of the simplex and you stick arrows on them and this has an orientation right there's now a notion of a outer surface and an inner surface or if you like an outwardly facing normal and an inward lis facing normal so if you just apply the right-hand rule then you can see the normal of this little surface piece points out of the board so these arrows define a notion of a normal of inward and outward facing normal inward is there that's the reverse orientation and this this notation is clearly redundant so the orientation handed to us by that particular order is exactly the same as the orientation handed to us by writing the simplex like that and so now we can reverse the orientation by flipping an arrow sorry flipping two hours right I'm flipping an arrow so that's the orientation that way but we could also have had the orientation the other way then the normal vector points now this way we and that's equivalent to going and they see I've got P naught at the top P 1 and P 2 here so the orientation of P 2 P naught P 1 sorry P 2 P 1 P naught is obviously equaling to a P 1 P naught P 2 which is obviously equal to P 2 P 1 P naught and again we employ the highly suggestive notation that that's equal to minus the orientation of the original simplex here so this is again just notational definition the minus signs of Earth it's not a minus sign we can't add and subtract these things yet we haven't given them a space to be edited and subtracted in so in general we're going to define this notation for all possible permutations of these points so we're gonna allow ourselves to flip the arrows on any edge we have this arbitrary notation here where hi is the permutation that brings 0 1 2 2 JKL so this is a definition of notation and you can see that this definition of the notation is coherent if you choose different orientations then the minus sign that you put in front here will be well-defined and now you see that's how we're defining orientation in two dimensions what about n dimensions will I wrote this up very suggestively because each of the things here can be extended to n dimensions [Applause] keep us one so this notation tells us when to synthesise are the same orientation or opposite orientations so this simplex here this convex hull of these K plus 1 points has the opposite orientation there's a minus sign here to the basic simplex when the sign of the permutation that map's these points to these points is minus 1 and it has the same orientation when they're the same all right I think we have time for boundaries so for a zero simplex otherwise known as a point we define the notation to mean take boundary of so for an oriented one simplex we're going to define the following notation so still with at the level of defining notation we're not yet interpreting this as - in an abelian group it's just notation at this point and then in general we define the boundary for a k-dimensional oriented k simplex it's a linear combination in quote marks because we still haven't given these things a space to live in so it's still notation and we're going to check later that's the notation is coherent with a well defined with respect to an abelian group defined by so you take the boundary of Sigma K and what you do is you subtract out one point from the k plus 1 places where it could be and then you put in a minus sign so that's how we're defining this thing called take boundary of it's this formal linear combination because at the moment it's all formal of K minus 1 sympathies according to this notation here you can see that that notation matches at least in the special case K equals 1 this notation here we'll do an example to end the lecture today and then in the next lecture will show that this gives a nice map between abelian groups it's the way show is maybe a bit strong argue let's do an example let's take the boundary of the standard oriented to simplex so let's follow this formula you delete point zero so that should be get p1 p2 and then you put a minus sign in front of the case where you've deleted point 1 and you put a plus sign for point two being deleted so that's the notation there and then D 3 P 1 P 2 P 3 minus P naught P 2 P 3 plus P naught P 1 P 3 minus P naught P 1 P 2 yeah yes is that not matching this point P naught oh goodness me there's an overall minus sign isn't there sorry I got carried away is this thanks now it works right yeah yeah this this I just calculated from this so this is the correct thing this is this is good this is uh this was not good all right I think we'll stop there for today then in the next lecture I'm going to show you how to do integration over sympathies in a manifold singular simplices and then we hope we'll get to something called Stokes theorem which will relate integrals over volumes of integrals over boundaries and then we'll be basically done with our differential geometry we'll head straight on in into symplectic geometry after that okay that's it thank you very much [Music]
Up Next

Persistent Homology: Topology in Data Analysis Explained
@VisualMath
3.9K views•2021-11-16

JEE Maths | Circles: Pole & Polar Explained with Equations
@TargetPublications
14.4K views•2019-02-23

Fourier Series Introduction: The Big Idea Explained
@DrTrefor
387K views•2021-05-03

The Mathematical Impossibility of Accurate World Maps
@Vox
23.3M views•2016-12-02
Related Study Plans & Knowledge Roadmaps
Structured learning paths in Mathematics