











Force is an external agent capable of changing a body's state of rest or motion, defined by Newton's second law as F = ma, with the SI unit being Newton (kg·m/s²). Forces are vector quantities with magnitude and direction, and can exist in two or three dimensions. The main types of forces include applied forces, reaction forces (such as ground reaction forces), normal forces (acting perpendicular to surfaces), and frictional forces (opposing motion). The principle of transmissibility states that a force can be moved along its line of action without changing the analysis. To resolve a force F acting at an angle θ to the x-axis, the x-component is F_x = F cos(θ) and the y-component is F_y = F sin(θ), enabling vector addition and equilibrium analysis in biomechanical systems.
Introduction to Biomechanics: Principles of Forces & Vectors
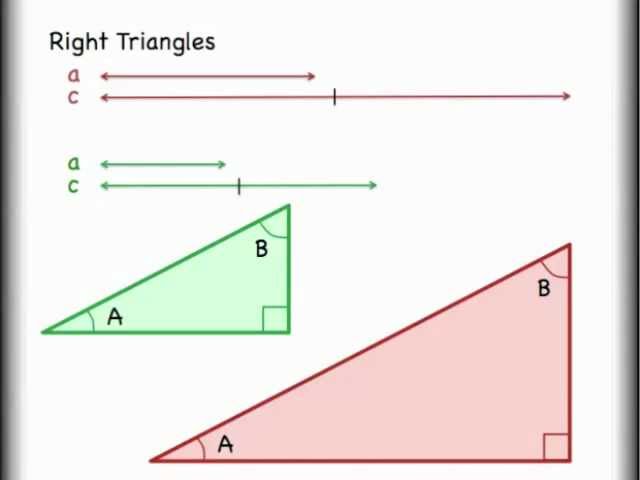
Added:[Music] thank you [Music] welcome welcome to this video on biomechanics in this video we'll be introducing some basics of mechanics we'll start with an introduction to vectors and how to resolve vectors so this is introductory mechanics in Statics and Dynamics so in this video will be starting with mechanics forces acting on a body what are the types of forces what is principle of transmissibility how to resolve forces in a couple of simple examples of how to resolve forces so we know what is force force is an external agent that is capable of changing a body's state of rest or motion that is if the body is at rest and if you would like to move that body from rest you need to apply a force r if the body is moving and you want to stop that body from moving then you need to apply a force to stop it so it is that agent that is capable of changing the state of motion OK State of rest or motion we know from high school that f is m a this is the Newton's Law that is the force is mass times the acceleration note that acceleration is a vector ok just come to that in a minute so Force f is M times a m is having unit kilogram acceleration is having the unit meter per second squared the s i unit of force is Newton which is equivalent to moving one kilogram Mass with an acceleration of 1 meter per second Square so that is kilogram meter per second Square the SI unit is Newton this is the SI unit in this equation the acceleration is a vector force is a vector Force can exist in two Dimensions or three dimensions for the purpose of this course we only deal with forces in two dimensions are the planar case but real life in real life biomechanics you almost always have 3D forces or forces that are acting in 3D So when you say force is a vector that means that it has a magnitude and a Direction so all the things that all the rules that apply for vectors also apply to forces types of forces you apply a force on an object or a body this is the applied force then you stand and the ground is applying a force on you which is why you are standing still you're almost always never standing still you're always fidgeting there's a little bit of oscillation that you are making as you are standing it's a small moments that you're making let's take a table or in this case this walker that is taken and this walker is kept on the ground it has four legs and it is standing still other than the vibration of the building for example otherwise it is standing still now the weight of this walker is acting through these four legs not necessarily equally if it is a symmetric design you might expect that to be equal but not necessarily equally now because I know that this walker is not accelerating downward it's not just going down I know that the ground or the floor is applying an equal and opposite Force on the worker this is why the Walker isn't static equilibrium ok so this force that is applied by the ground on that Walker is called reaction force just like when you are standing still your weight is applied through the feet on the ground and the ground is applying an equal and opposite force on your feet this is the reason your feet are not going down you are not accelerating downwards right so that force is called reaction force specifically when the ground is supplying this force on your feet that is a special name for that is called as a ground reaction force in ah postural balance and while analyzing gate and walking we call this forces ground reaction force ok so that is the reaction force consider this lady she is holding a ball that's let's assume its weight is 50 Newtons ok so she is holding a ball weighing 50 Newtons so that wait because she is on planet Earth is acting in that direction is it not that direction but the ball itself is not accelerating downwards acceleration due to gravity is acting on it but the body is not accelerating downwards why is that because someone is holding it like I am now holding this pen why is the pen not going down because I am holding it with my hand that means I am applying an equal and opposite force on this pen so that it does not accelerate suppose I were to suddenly remove I were to suddenly remove my hand what will happen let's see what will happen so that is it is there like this suppose I am removing my hand like this what happens there is an acceleration that happens I'm just holding this thread so that the pen will not fall down under you know the instruments will not be disturbed here but you see what happens suddenly I am removing this that is the acceleration that you are seeing here that means the reason why this pen is in equilibrium is because this hand is applying an equivalent opposite force on this pen so that it remains in equilibrium ok so this 50 Newton force is applied by this lady or her hand on this ball that is why it is in equilibrium okay this Force that is applied by her by this hand on the body can be considered to be a active force or reaction force depending on how you are looking at it ok because you might look at this from the Viewpoint of the ball or the hand if you are looking at it from the Viewpoint of the hand then the force that is applied by the lady is the applied force and the balls force can be the reaction force but generally it makes sense for us to consider this Force as the active Force and the force applied by the hand on the ball as the reaction force OK this is the reaction because if there was no ball then this force will not be applied that is the reaction force likewise here is a a cart that is moving on a rail similarly there will be some normal reaction force critical to note the use of the word normal that means these forces are only acting normal to that cut OK not in any other direction ok ok then you have force in a spring we know this from high school physics let us say that the spring is having a constant of k the force in this spring is proportional to the deformation or the displacement that this spring undergo so I know that this force is k x right one more thing that we know is the action of gravity I will explain that in a previous example one other thing is the so-called frictional force this is essentially a reaction force to the applied force Etc it always acts in a direction opposite to that of the applied force so here what is shown is there is a block on a table or on the floor that is being pulled or pushed in a particular direction right so that is this Force shown in red let us call this 100 Newton Force being applied on this block for example now because the surfaces of the block and the table are rough or not smooth because of this reason there will be a force that will oppose motion of this block on the table that force will always be opposite to the direction of the plate force that means if the applied force is not along this red Arrow that means if the applied force is not along the red arrow shown but rather along that red arrow then the frictional force will be along this direction so it always acts against the direction of the application it is a its a reaction force that is developed when this kind of ah surfaces are involved in particular when the surfaces are not considered to be smooth most practical surfaces are not smooth so in this picture the red arrow indicates the applied force on this block what does the blue signify the Blue Force is the force that is normal to the block this is the force that is going to overcome gravity let us say this block is having the weight 1000 Newtons then because this block is not accelerating downwards this table or the surface is applying a thousand newton force in the upward direction that is shown in blue here this is the normal force the frictional force is shown in green here this is the frictional force this is a tangential Force that is acting tangent to the surface this is called tangential Force but we simply call it as frictional force how do we know the direction of the frictional force it is always opposite is the direction of the applied force depending on the direction of the applied force I will decide the direction of the friction Force some details are missed out here the magnitude of the frictional force Visa with the magnitude of the normal force will give us an idea of the amount of friction for example uh the angle at which the resultant is acting will give us an idea of the type of ah friction that is happening and the amount of friction that is happening right some details I am skipping here but for the purpose of this discussion this assumption these are the various types of force some types of force that we discussed there are other types of forces that we will not be discussing here this is expected to be sufficient for the purpose of this course an important principle while dealing with forces is the principle of transmissibility of forces what is this is the idea that I could change I could move the point of application of force along the line of action of force without changing any other analysis or any other factor in the analysis that is let us say in this case ah Force F1 and of course F2 are acting at this point O now I know that the line of action of forces along that line the line of action of this forces along this line right now I can move this F1 to X from this point and F2 to act from this point without changing the analysis this principle is called as the principle of transmissibility of forces important that you cannot move it anywhere you want you can only move it along the line of action of that Force so for F1 it can only be moved along this line infinitely anywhere but I cannot move it any other two but I cannot move it to any other point important to remember that that also means that if a force is acting let us say there is this point O and that is one force that is acting in this direction and one force that is acting in that direction I could bring this First Act from o and this first also to act from that is a very convenient Arrangement that is a very convenient notation change that I could make that will make my analysis simpler so I could not only move it along the positive direction I could also move it along the negative Direction so although the force is starting here and acting in this direction I could essentially pull this force and make an act from this point that wouldn't change the analysis so according to that this this is a very convenient ah principle that is used in the analysis of forces quite frequently right some other examples are given here so I could for example from o f 1 is acting in this direction and F2 is acting in this direction right I could assume this to be you know F1 is acting like this and F2 is acting like this we know from High School Vector analysis that these two are essentially the same using triangular parallelogram law we know that these things are essentially the same a question is how do we resolve forces we'll spend some time on this topic because in future classes I will be writing out immediately the resolved vector while solving problems so I'll spend a few minutes on this topic let us assume there is a force f acting in this direction shown the direction is given by some Theta to x axis the X Y axis is this the x axis is given here so that is the X Y axis anyway I am writing it again it's already given here but not so that is the that is the X Y axis so at an angle of theta to x axis this Force f is acting now I would like to know the components of this Force along the X and Y axis or I would like to resolve this Force into its components for the purpose of this discussion I am only doing it in 2D remember that force is a vector and it can exist in 3D space and I could also result between 3D if there is a need but since here we will be dealing only with 2D for now I am only solving this one 2D ok so the question is I have F and I know the value of F and I know the direction at which this F is acting with respect to the x axis that is Theta these two are known what is it that is required I want to know what is the value of f X and f y are the X and Y components I would like to resolve this Force F into its corresponding X and Y components why do you have to do this because you know f I know if what is the point in resolving this into corresponding X and Y well you know in this problem you know F already there is nothing else there is no other force that is there but suppose there is a different problem in which you know there is one more force that is also acting from o which I am going to call as sum F2 okay now I would like to know what is the total force that is acting for example and what is the direction now that is not in in this case it appears you know trivial in in some cases it's not actually so trivial you cannot simply add them because force is a vector you cannot simply add them two vectors are equal only when their components are equal so it makes sense for me to componentize or resolve this F1 F2 into corresponding X and Y components and then sum them in the corresponding components and then find the final result something like that so this is an expected application and as you solve problems you will realize what is the use of this so coming back what is the problem that we are dealing with we have f that is known you have been given f is a force that is acting in Theta Direction at an angle of theta to x axis what is asked I would like to know the corresponding X and Y components of this Force this is what is asked well ok how do I find this now for finding the X component f x consider the right triangle I know this is high school physics but please bear with me because there are some students who may be taking it from other backgrounds other than mathematics who may need this refresher consider this right triangle oaf right that is 90 degrees in this the hypotenuse is of ok what is sine Theta we know sin Theta is opposite side by hypotenuse since this is Theta sine Theta is f a or rather a f divided by o f o f is the hypotenuse ok but we know the value of of that is the magnitude of the force f is it not ok that is AF by F the force case likewise I am writing what is cos Theta cos Theta is adjacent Side by hypotenuse that is o a divided by of and that is actually o a divided by the magnitude of the force F we know that the hypotenuse is the magnitude of the force F and I have told you already that f is given you know f now what is the question the question is find f x and f y is it not f x is o a is it not f x is o a and that is actually f cos Theta is it not because this because cos Theta cost it as y a by F that means that o a is f cos Theta so the component of this Force along the x axis is f cos Theta the component of this Force along the y axis is o b but that length o b is the same as the length a f did not it's the same and what is AF that is f sine Theta so by this we understand that the component of F in the x axis is f cos Theta for this problem okay depending on where Theta is this might change okay so this isn't a standard so you cannot use this everywhere cos Theta cos Theta you cannot do that okay depending on where Theta is as we will solve problems you will realize that this will change and f y is F sine Theta for this problem now let us look at an example ok this is the X Y axis given please note this this is the X Y axis that is given the question is resolve this Force F into its corresponding X and Y components note something to note is this bar is at an angle of theta from the horizontal where the horizontal is the x axis now how do I solve this problem well same principle it's scary looking but it's not scary right same principle so what do I do I try to find the cosine of 90 minus Theta but why is that why do I find cosine of 90 minus Theta well because I would like to find that component right and that component is the X component it turns out that is that component I am interested in finding that distance that is O A by of is it not in this triangle in this triangle oaf that is the O A by of and O A then is o f of COS of 90 minus Theta note that why is this 90 minus Theta is it confusing because this Force itself is acting at an angle of 90 degrees to this bar but the bar itself is not horizontal the bar itself is inclined at an angle of theta to the horizontal because of this reason this angle happens to be Theta why is that this is you know alternative angles because this angle happens to be Theta because of the treason because the total angle is 90 degrees then this angle becomes 90 minus Theta okay so f x then is f times of 90 minus Theta likewise I am interested in finding that a f a f is sine of negative minus Theta that distance this is sine of 90 minus Theta times o f is it not that because sine of 90 minus Theta is a f by of so that would be that would mean that a f then is y f times sine of 90 minus Theta but y f is the force f so the Y component is F times sine of 90 minus Theta let us look at one more example now the question is resolve the force f along X Direction and Y Direction how would you solve this problem so the directions are given that is the direction that is given ok now I am interested in resolving this Force along the X Direction and Y Direction now the horizontal is already drawn for your reference that is the horizontal right note that the bar is inclined at an angle of 30 degrees to the horizontal the force is acting at an angle of 20 degrees from the bar you can essentially add them to get the angle from which the force is acting from the horizontal that is 50 degrees I could get that okay that is the X Y axis for example that force is acting at this is a value of 10 Newtons is acting at an angle of 50 degrees from the horizontal ok now I am interested in finding its X component and Y component like not now what is f x f x is the component of this Force along the X direction is it not along this direction now in this right triangle in this right triangle the force is the hypotenuse and I am interested in finding the adjacent side that means I will have to find the cosine is it not so f x then would be F cos Theta or 10 times cos 50.
I am not solving the numeric I will leave it for you as an exercise to solve then f y is that distance is it not or rather this but these two are actually numerically equal also the directions are equal so and according to principle of transmitter I could actually move it where I want fo is actually 10 times sine Theta what is the direction in which it is acting that is the question because how would you solve this if I am solving this in this x y axis for this positive x y axis then how do I do this is because this distance is because this angle is 90 Plus 50.
I have to say sine of 90 plus Theta I will have to say that and then solve it because I am interested in finding the answer with respect to the positive Y axis the other way of saying that is simply that it is 10 sine Theta in the negative y direction because this is the direction that I am finding with this if you use some intuition this is not too difficult because that is in the negative y direction that is minus 10 sin Theta again I am not solving the numerics I request you to please check this the numerical answers for this problem so with this we come to the end of this video in this video we saw some examples of resolving forces principle of transmissibility and forces and the types of forces that are acting on our body thank you very much for your attention [Music]
Up Next
Static Equilibrium: Tension, Torque, Beam, and Ladder Problems
@TheOrganicChemistryTutor
1.7M views•2016-10-07

How Tuned Mass Dampers Stop Structures from Shaking
@MinutePhysics
573K views•2018-08-28

Deriving the Wave Equation: Plane Waves & Refractive Index in Optics
@nptel-nociitm9240
6.8K views•2022-09-26

The Blue LED: A Decade-Long Scientific Challenge Explained
@veritasium
46.5M views•2024-02-08
Related Study Plans & Knowledge Roadmaps
Structured learning paths in Physics